
Training data for robotics AI
Prepare camera images, video demonstrations, and task records for robot perception and manipulation. Keep object labels and action context connected.
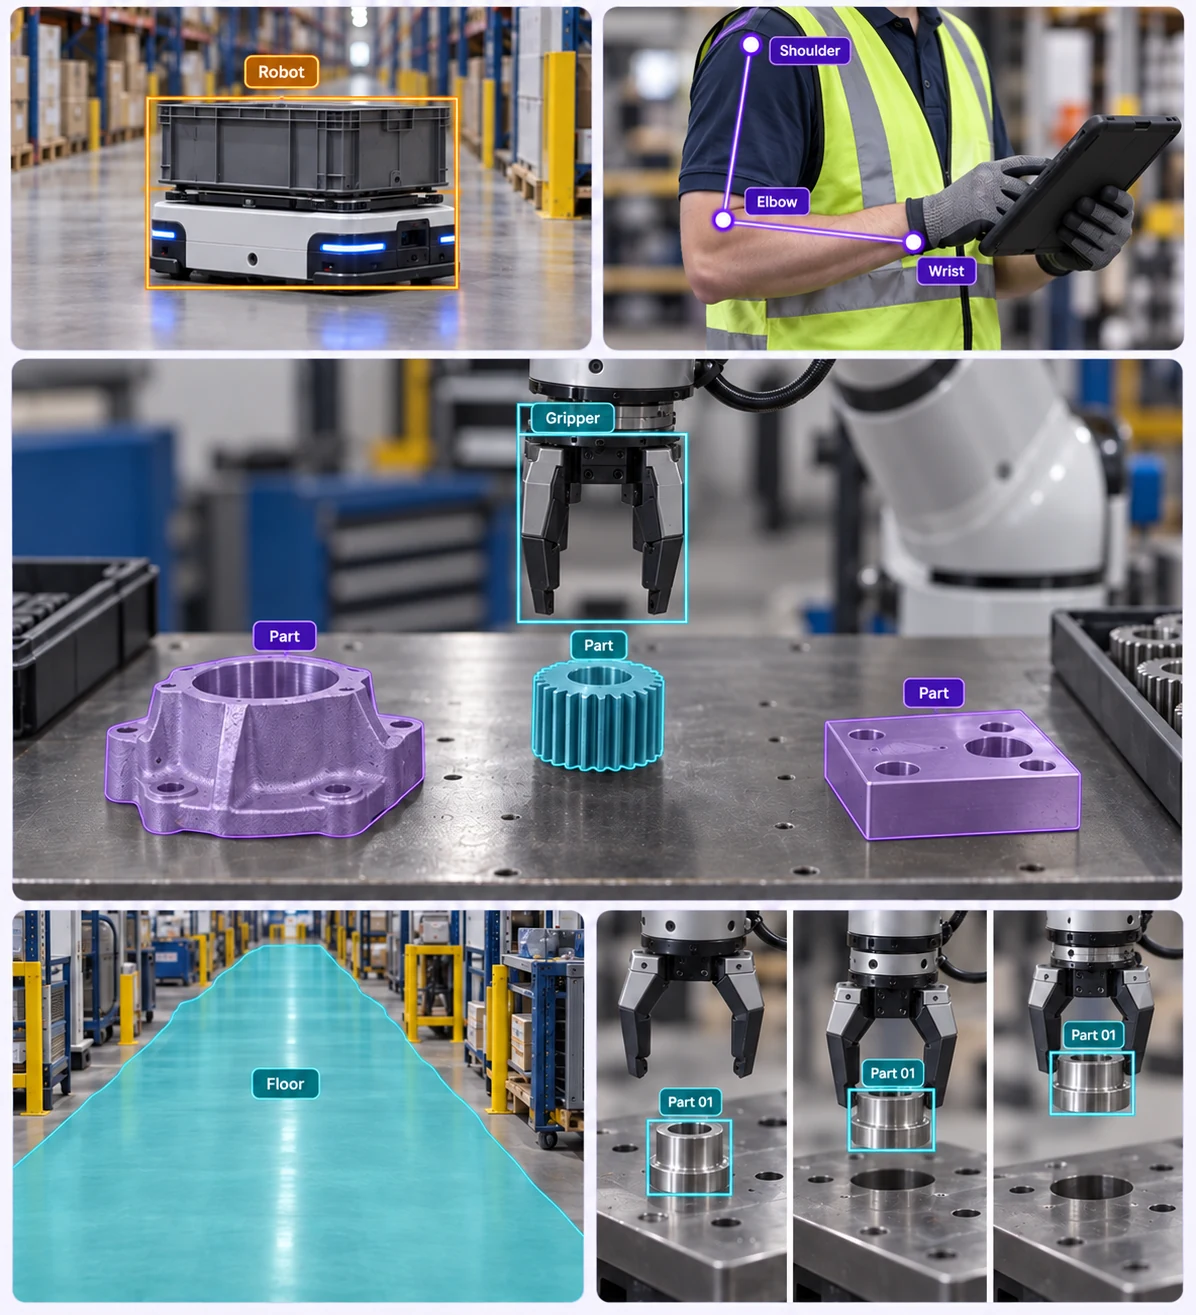
Annotation use cases for robotics
Turn source data into clear, task-specific training examples.
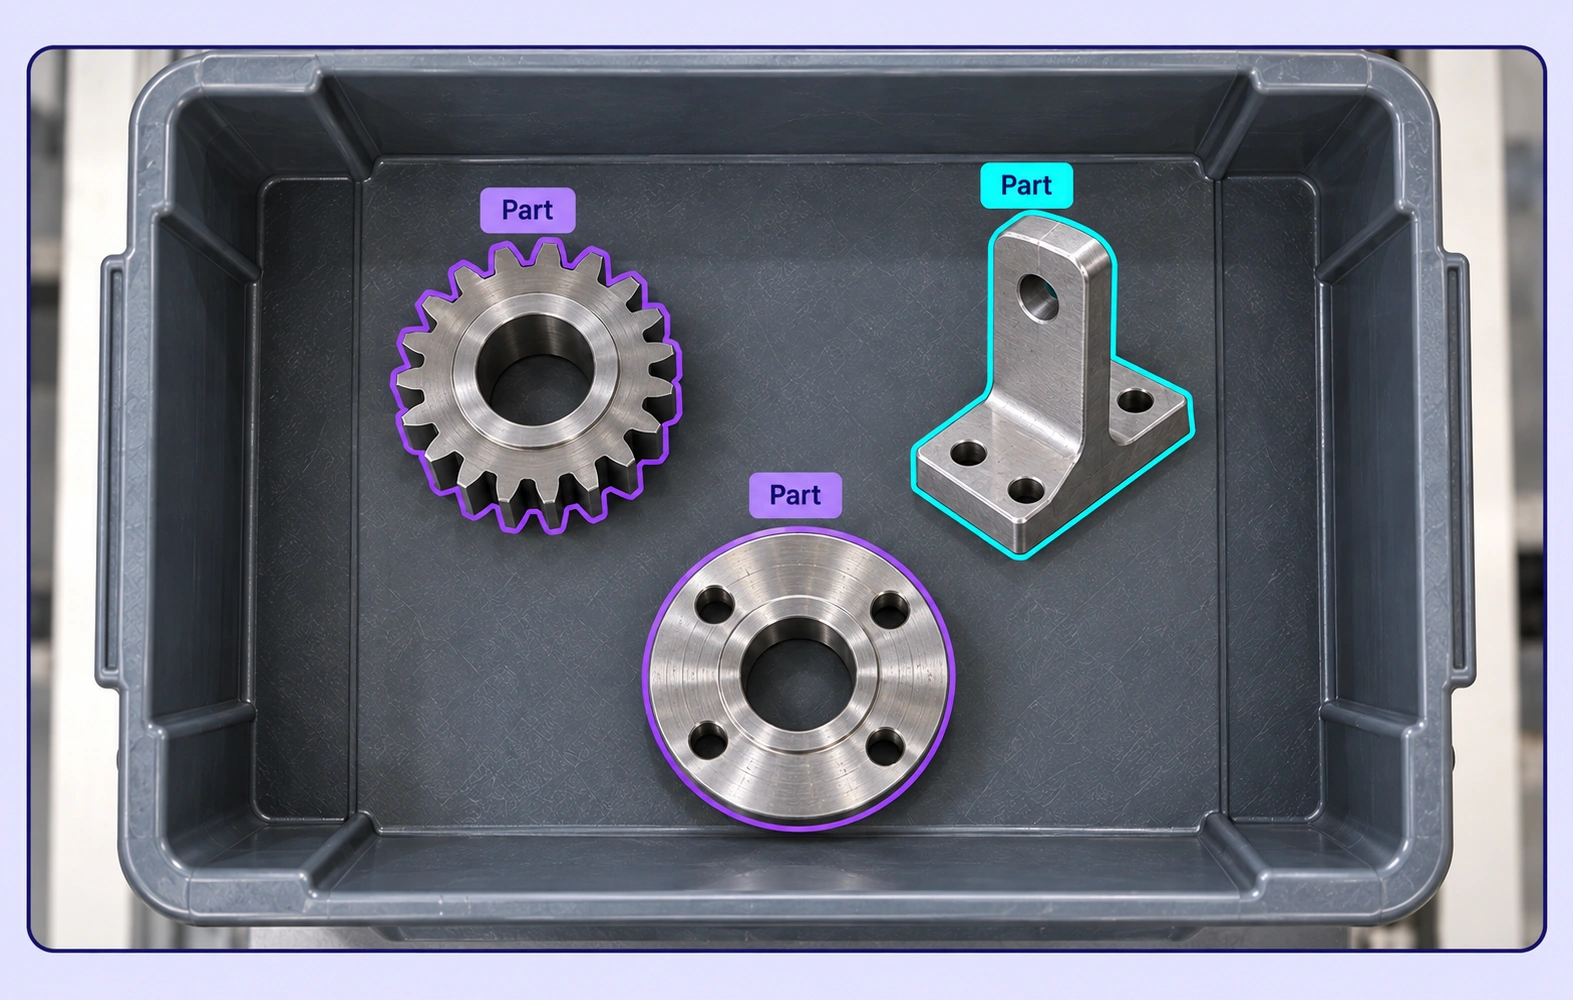
Object boundaries
Outline individual parts in cluttered scenes for consistent instance segmentation.
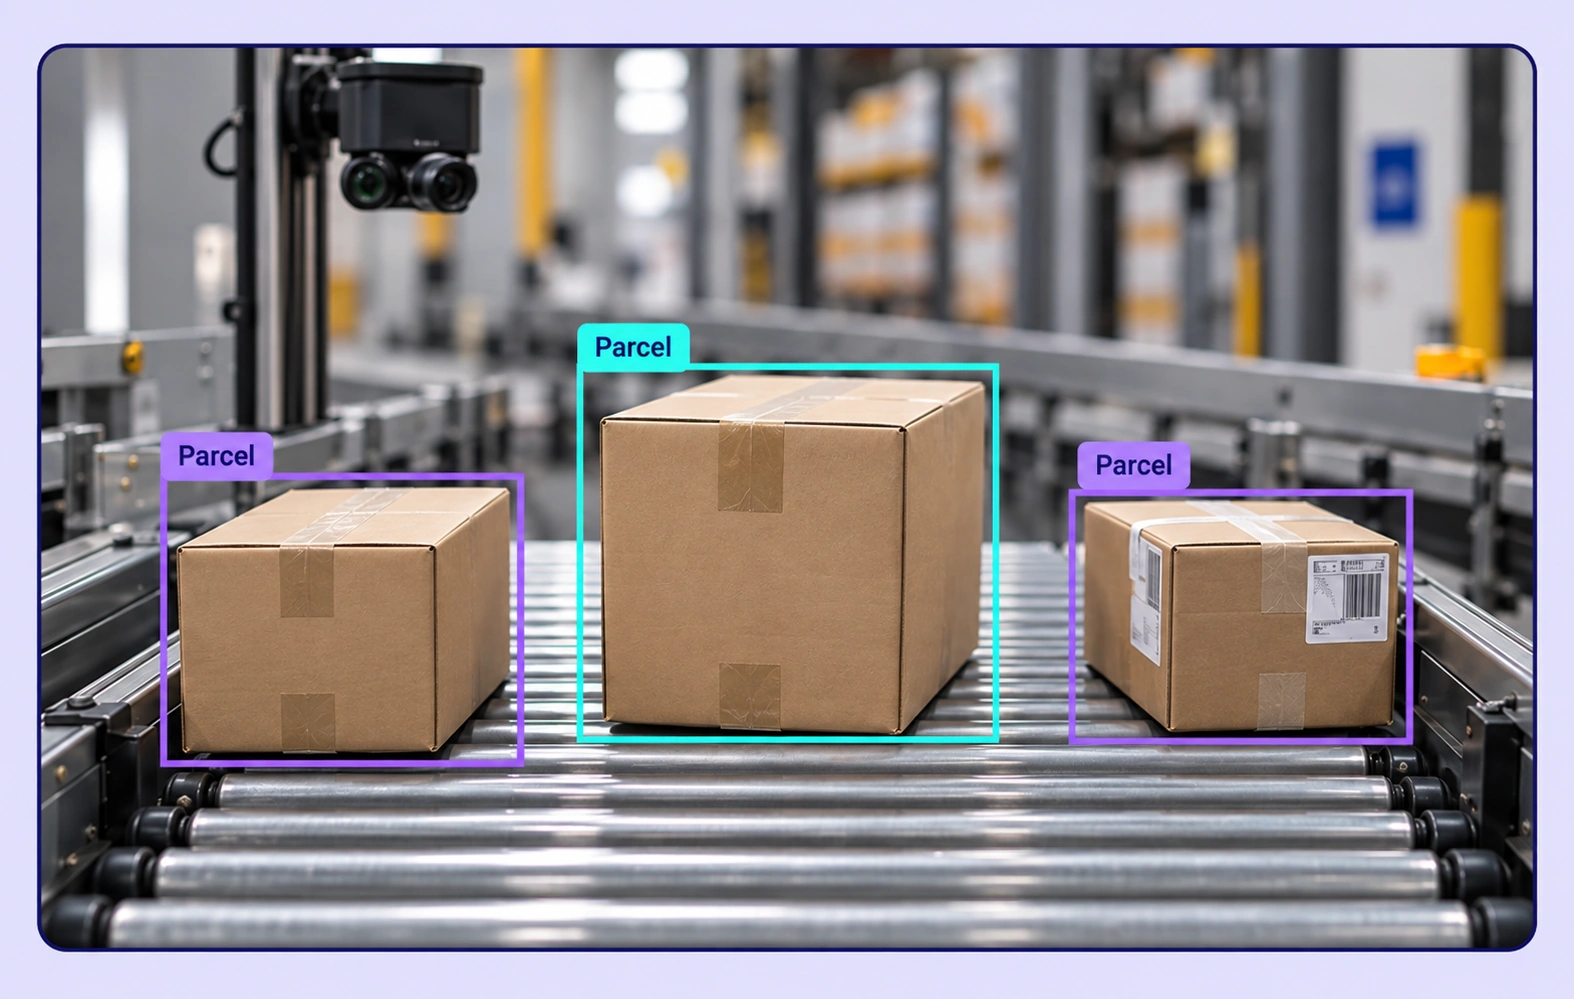
Parcel detection
Label each parcel separately to train robot-camera object detectors.
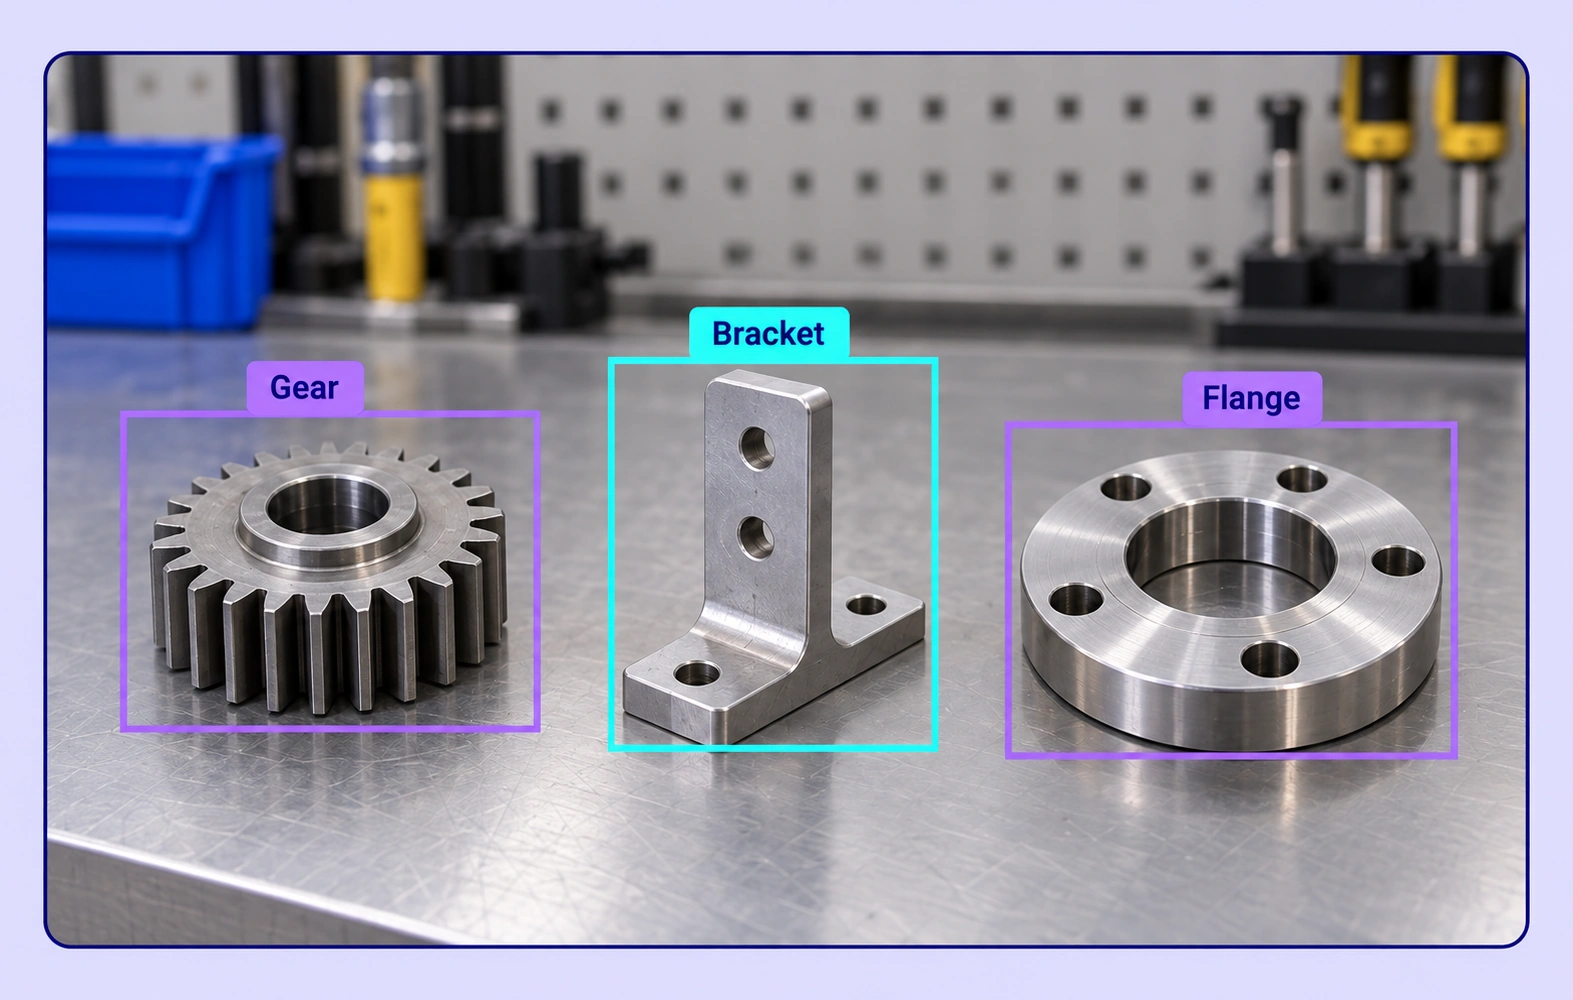
Parts and properties
Use shared classes and properties to distinguish gears, brackets, and other components.
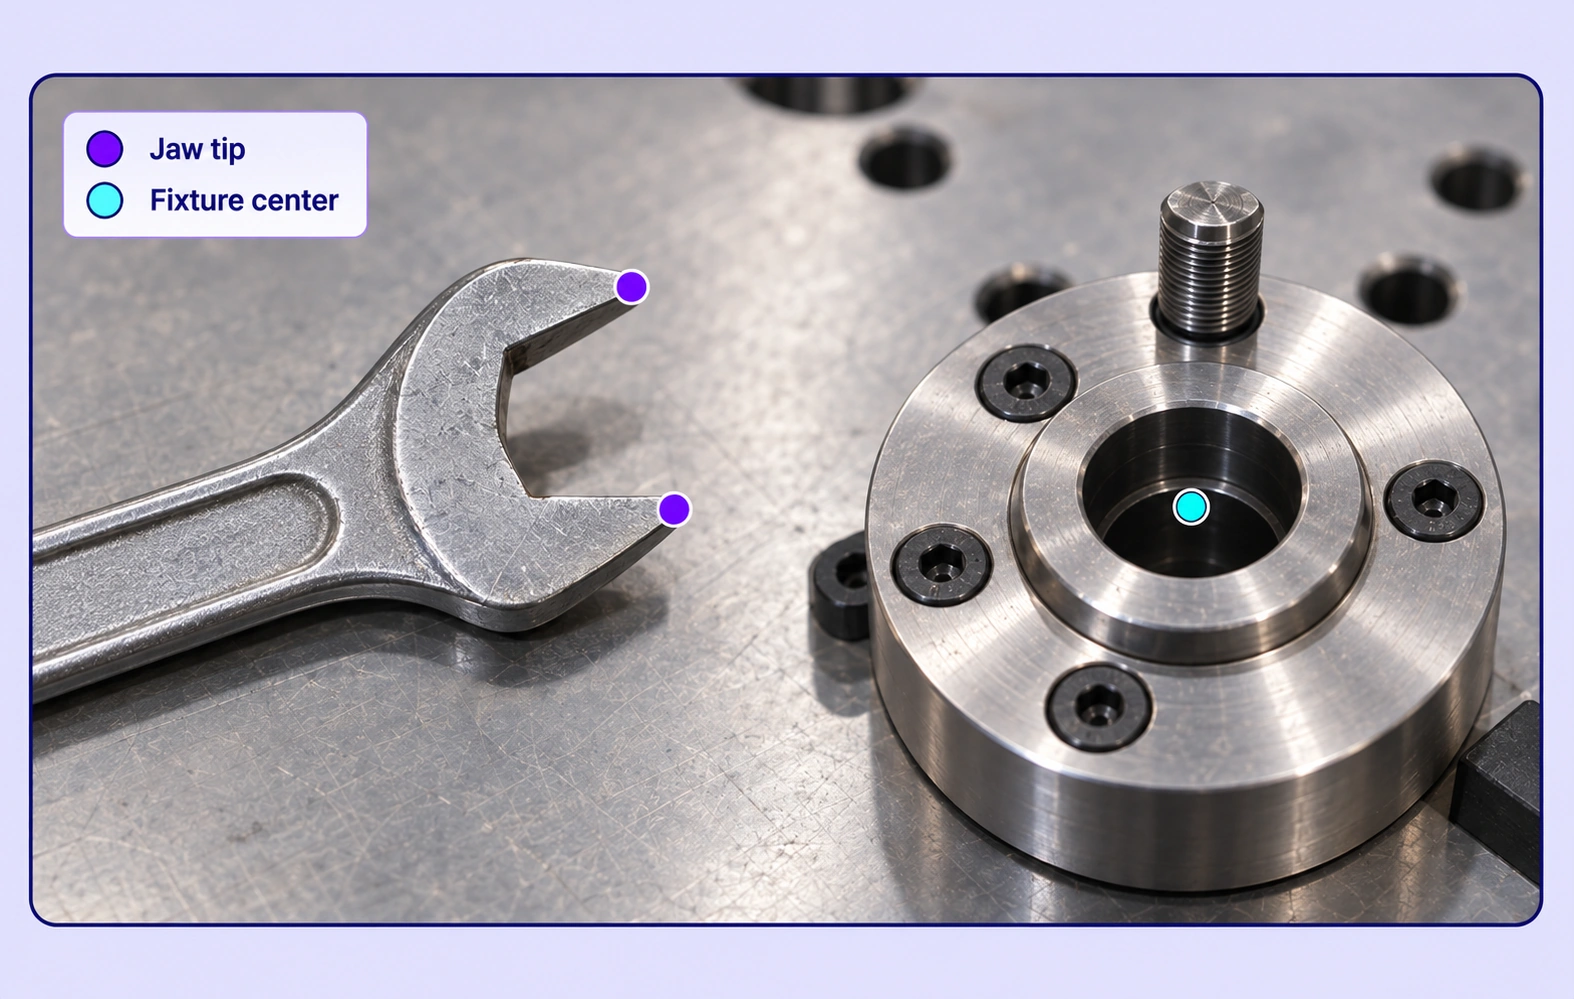
Landmarks for manipulation
Place keypoints on task-relevant tool tips and fixture centers.
Built for AI Data at Scale
Connect data curation, shared label definitions, review, and dataset versions in one workflow.
15X
Faster robotics data annotation
Label perception and demonstration data with unified tools and review workflows.
60%
Less time on data operations
Automate curation, management, and versioning of robotics datasets.
5X
Lower Training Data Costs
Reusable ontologies and governed quality control reduce labeling and review rework.
Labels that preserve source context
Match the annotation geometry and properties to your model’s task.
Instance segmentation
Outline each visible part separately, including touching objects. Define how to handle occluded edges so every annotator follows the same boundary convention.
Task-specific keypoints
Use a fixed keypoint definition for tool tips and fixture centers. Inspect landmark placement across orientations before using these examples for manipulation models.
Robotics FAQs
What is data annotation for robotics?
Data annotation adds defined labels to source data so models can learn a specific task. For robotics, examples include object boundaries and parcel detection. Unitlab connects this work in its data annotation platform.
Which data types can teams annotate?
Choose the tools that match the source data: image annotation, video annotation, multimodal annotation. Keep linked sources together when the task requires shared context. Confirm input formats and annotation requirements before starting a project.
Which robotics use cases can I explore?
Explore robotic object recognition and robot demonstration annotation for focused labeling examples. These solution pages explain the training-data task; the linked modality pages describe the annotation tools.
How do I keep annotation rules consistent?
Define classes, required properties, and boundary rules before labeling. Use examples such as object boundaries to resolve ambiguous cases. See the classes and annotation types guide.
How do I select representative training data?
Use data curation to inspect examples and filter available metadata. Plan coverage across objects, workspaces, camera viewpoints, and task stages, then check for missing or overrepresented conditions before annotation.
How are annotations reviewed before training?
Use annotation quality assurance to inspect labels against the task guidelines. Consensus helps compare annotator agreement; Quality Gate stages apply configured checks before work advances. Route uncertain examples to the appropriate reviewer.
What is the difference between a dataset version and an annotation release?
A dataset version records a source-data selection; an annotation release packages the annotation outputs for downstream use. Use dataset management to inspect and organize data, and consult the guide to annotation releases before preparing training exports.
Can I export data and connect my training pipeline?
Choose an output format supported for your annotation task and validate the result with your training code. Read the export formats guide and the API, SDK, and CLI documentation for automation and integration options.
How do I get started?
Start with a representative sample, a clear label specification, and an agreed review process. Read the image annotation documentation or discuss your workflow with the Unitlab team.
Need help defining your annotation workflow?
Talk to UnitlabBuild your robotics dataset
Bring data selection, annotation, and reviewed dataset delivery into one workflow.
Talk to sales


